MIT 2.009 · Blue Team · Fall 2026
MORTAR |
Masonry Inspection Robot
MORTAR is our team’s suspended robot for visual and tapping inspection of building façades, aiming to reduce setup time, cost, and risk for inspectors. I developed the mechatronics architecture and originated the solenoid tapper concept.
Mechatronics · CAD & DFM · Acoustic inspection Updated November 2026
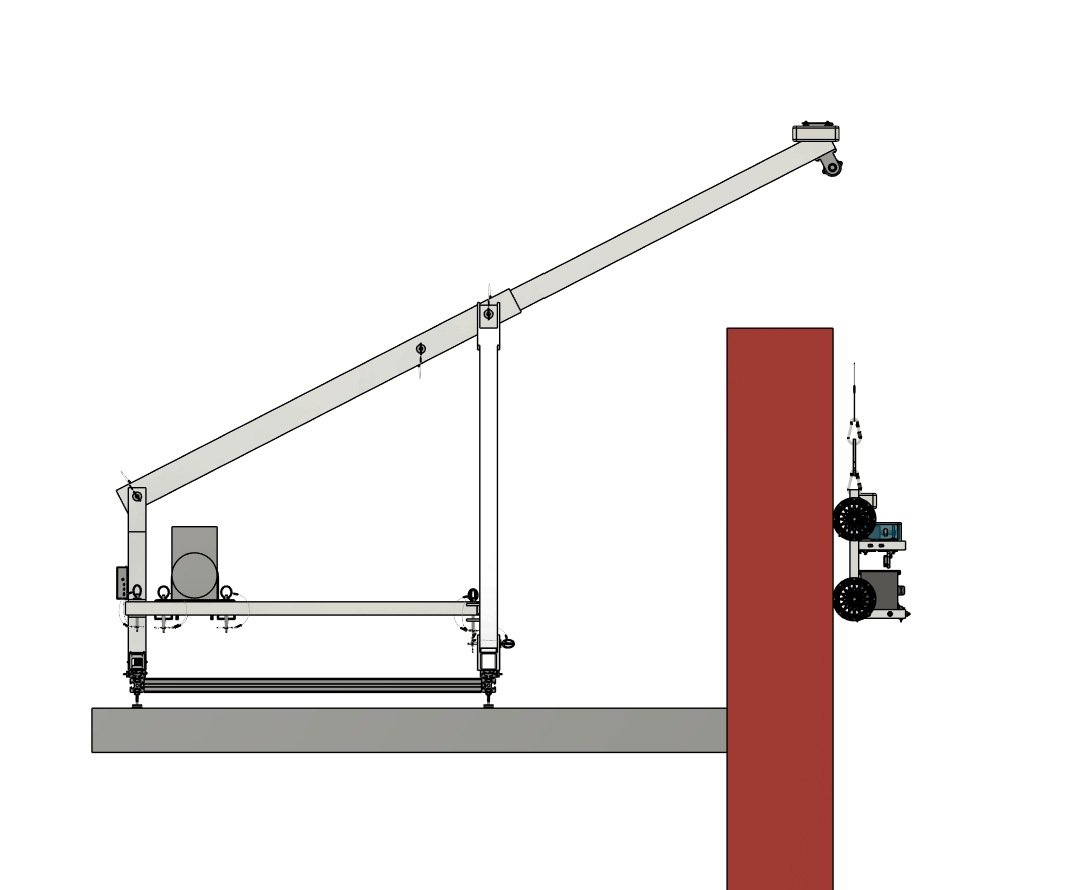
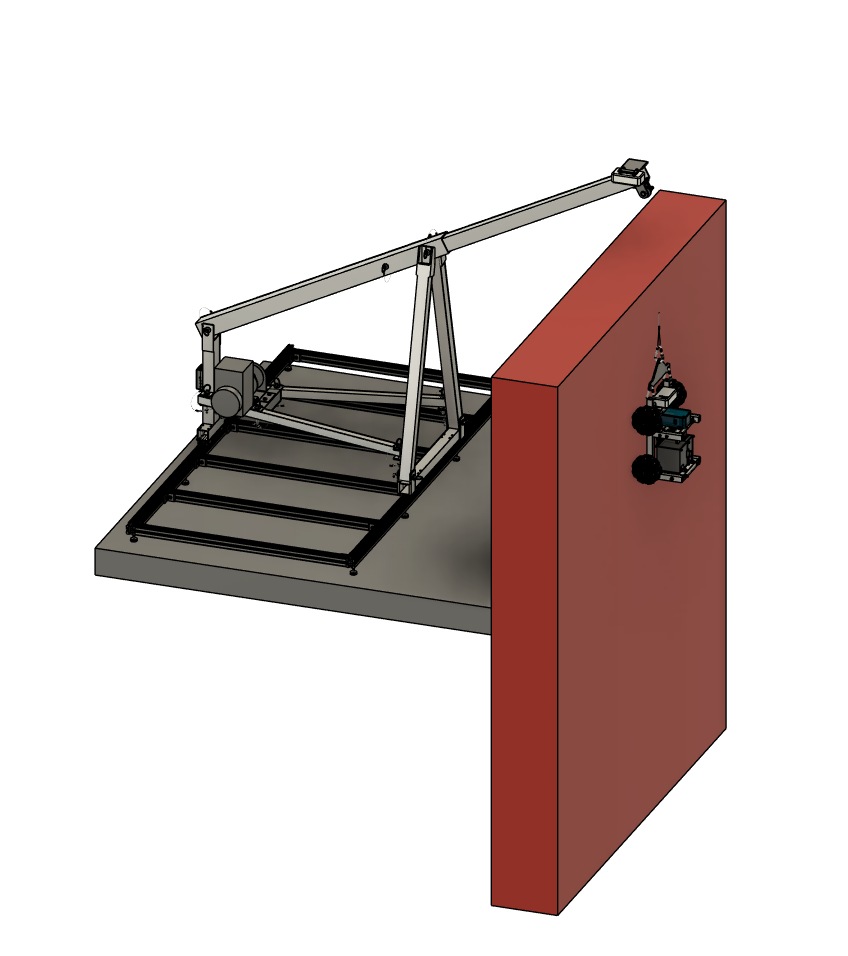
The complete system
Inspect the façade
from the rooftop.
A rooftop outrigger positions the suspended payload along the wall. Live video supports close-up visual inspection, while a solenoid tapper and audio capture provide sounding information. Encoder-based positioning links observations to locations for the inspector to flag.
01 My contribution
Cross-disciplinary engineering.
- Mechatronics architectureDesigned the sensing, communications, and control paths between the robot, rooftop, and inspector.
- Solenoid tapperOriginated the solenoid tapping concept and built the working prototype, including wiring, driver selection, and Arduino control.
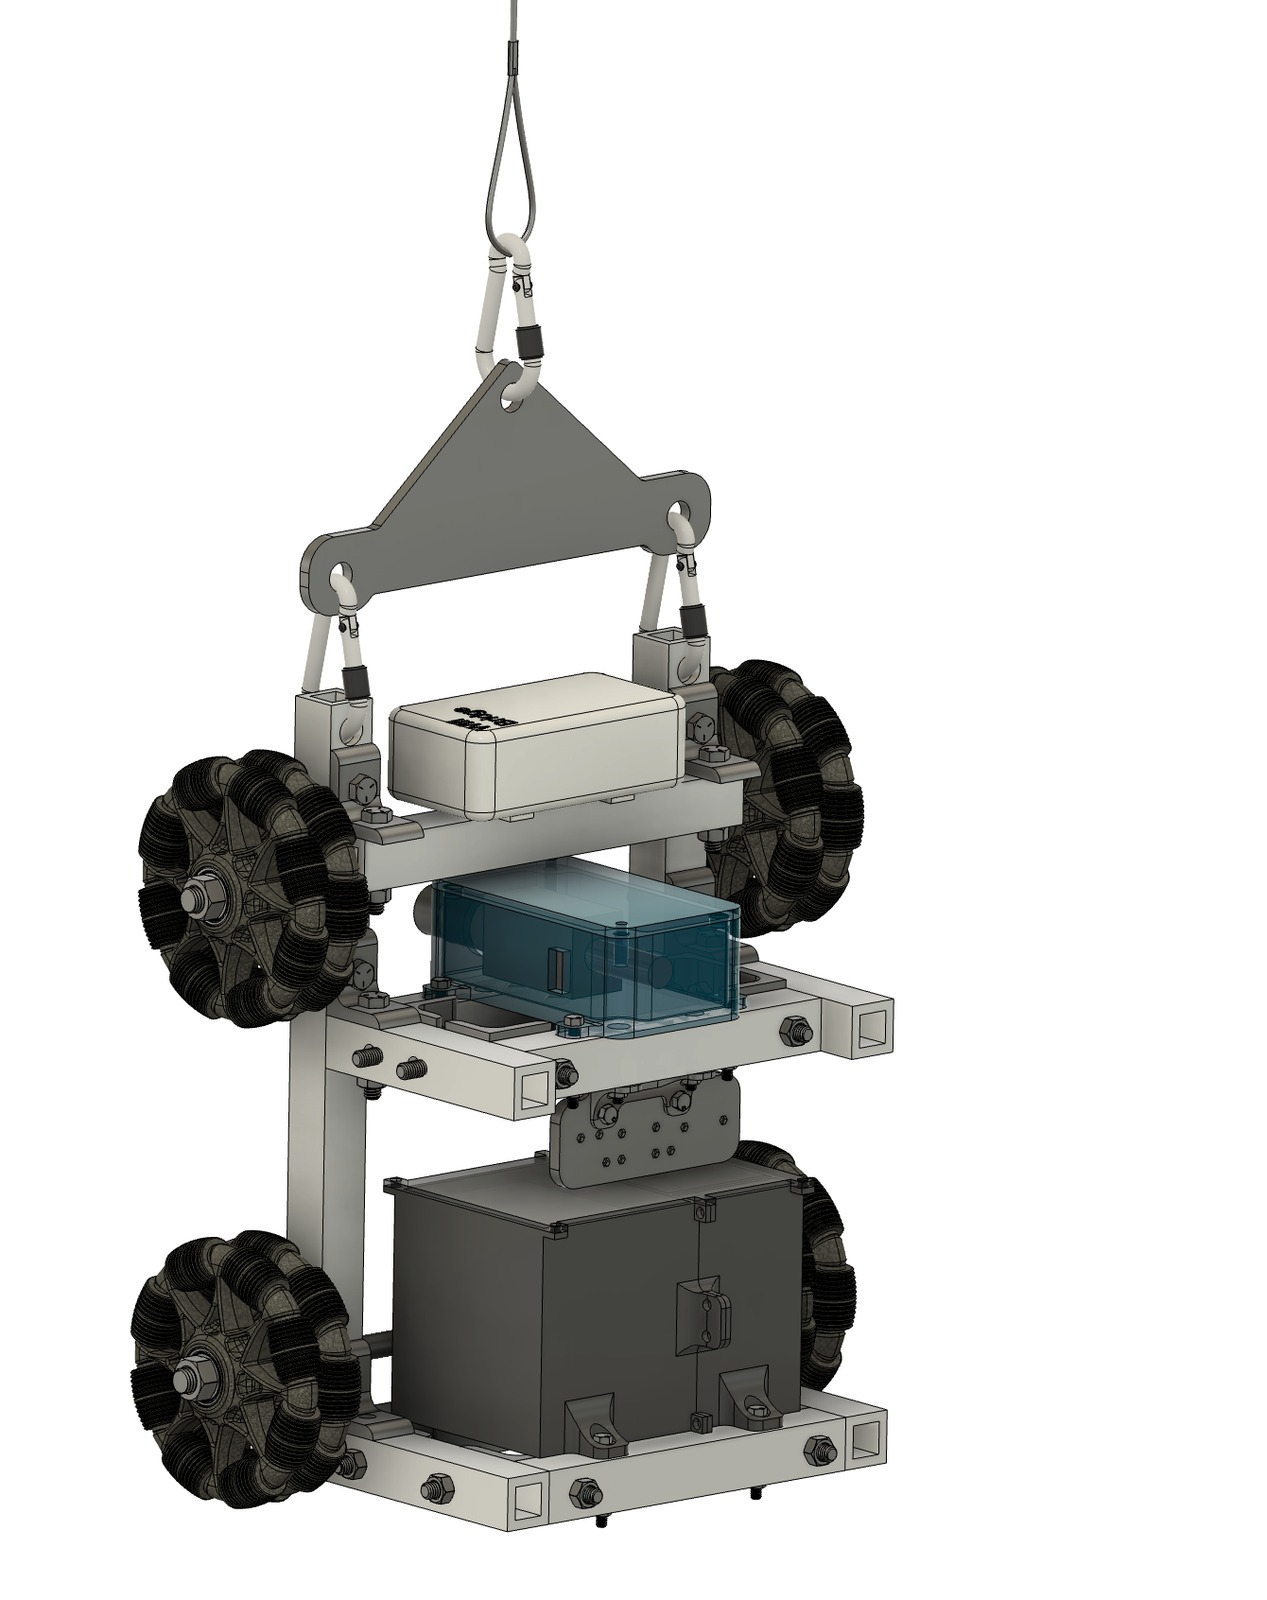
- Mechanical integrationContributed to CAD and component integration with the mechanical subteam. The payload and enclosure CAD shown here reflects shared team work.
02 My mechanism
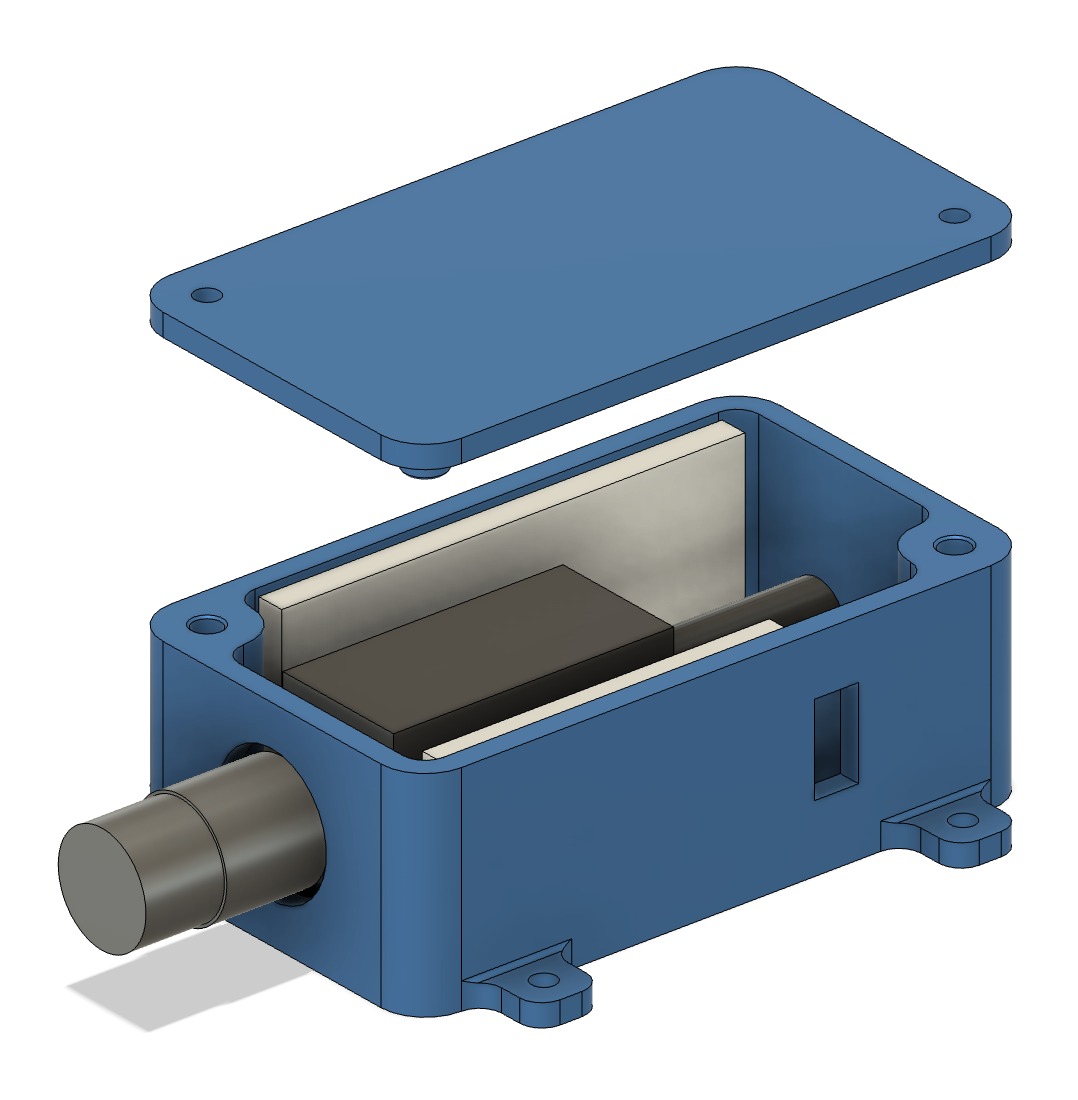
The solenoid tapper.
I built and programmed an adjustable tapping prototype using an Arduino Nano and MOSFET driver. Iteration focuses on the strike, spring return, and mechanical isolation to keep actuator noise out of the acoustic recording.
03 System design
Connecting the roof and robot.
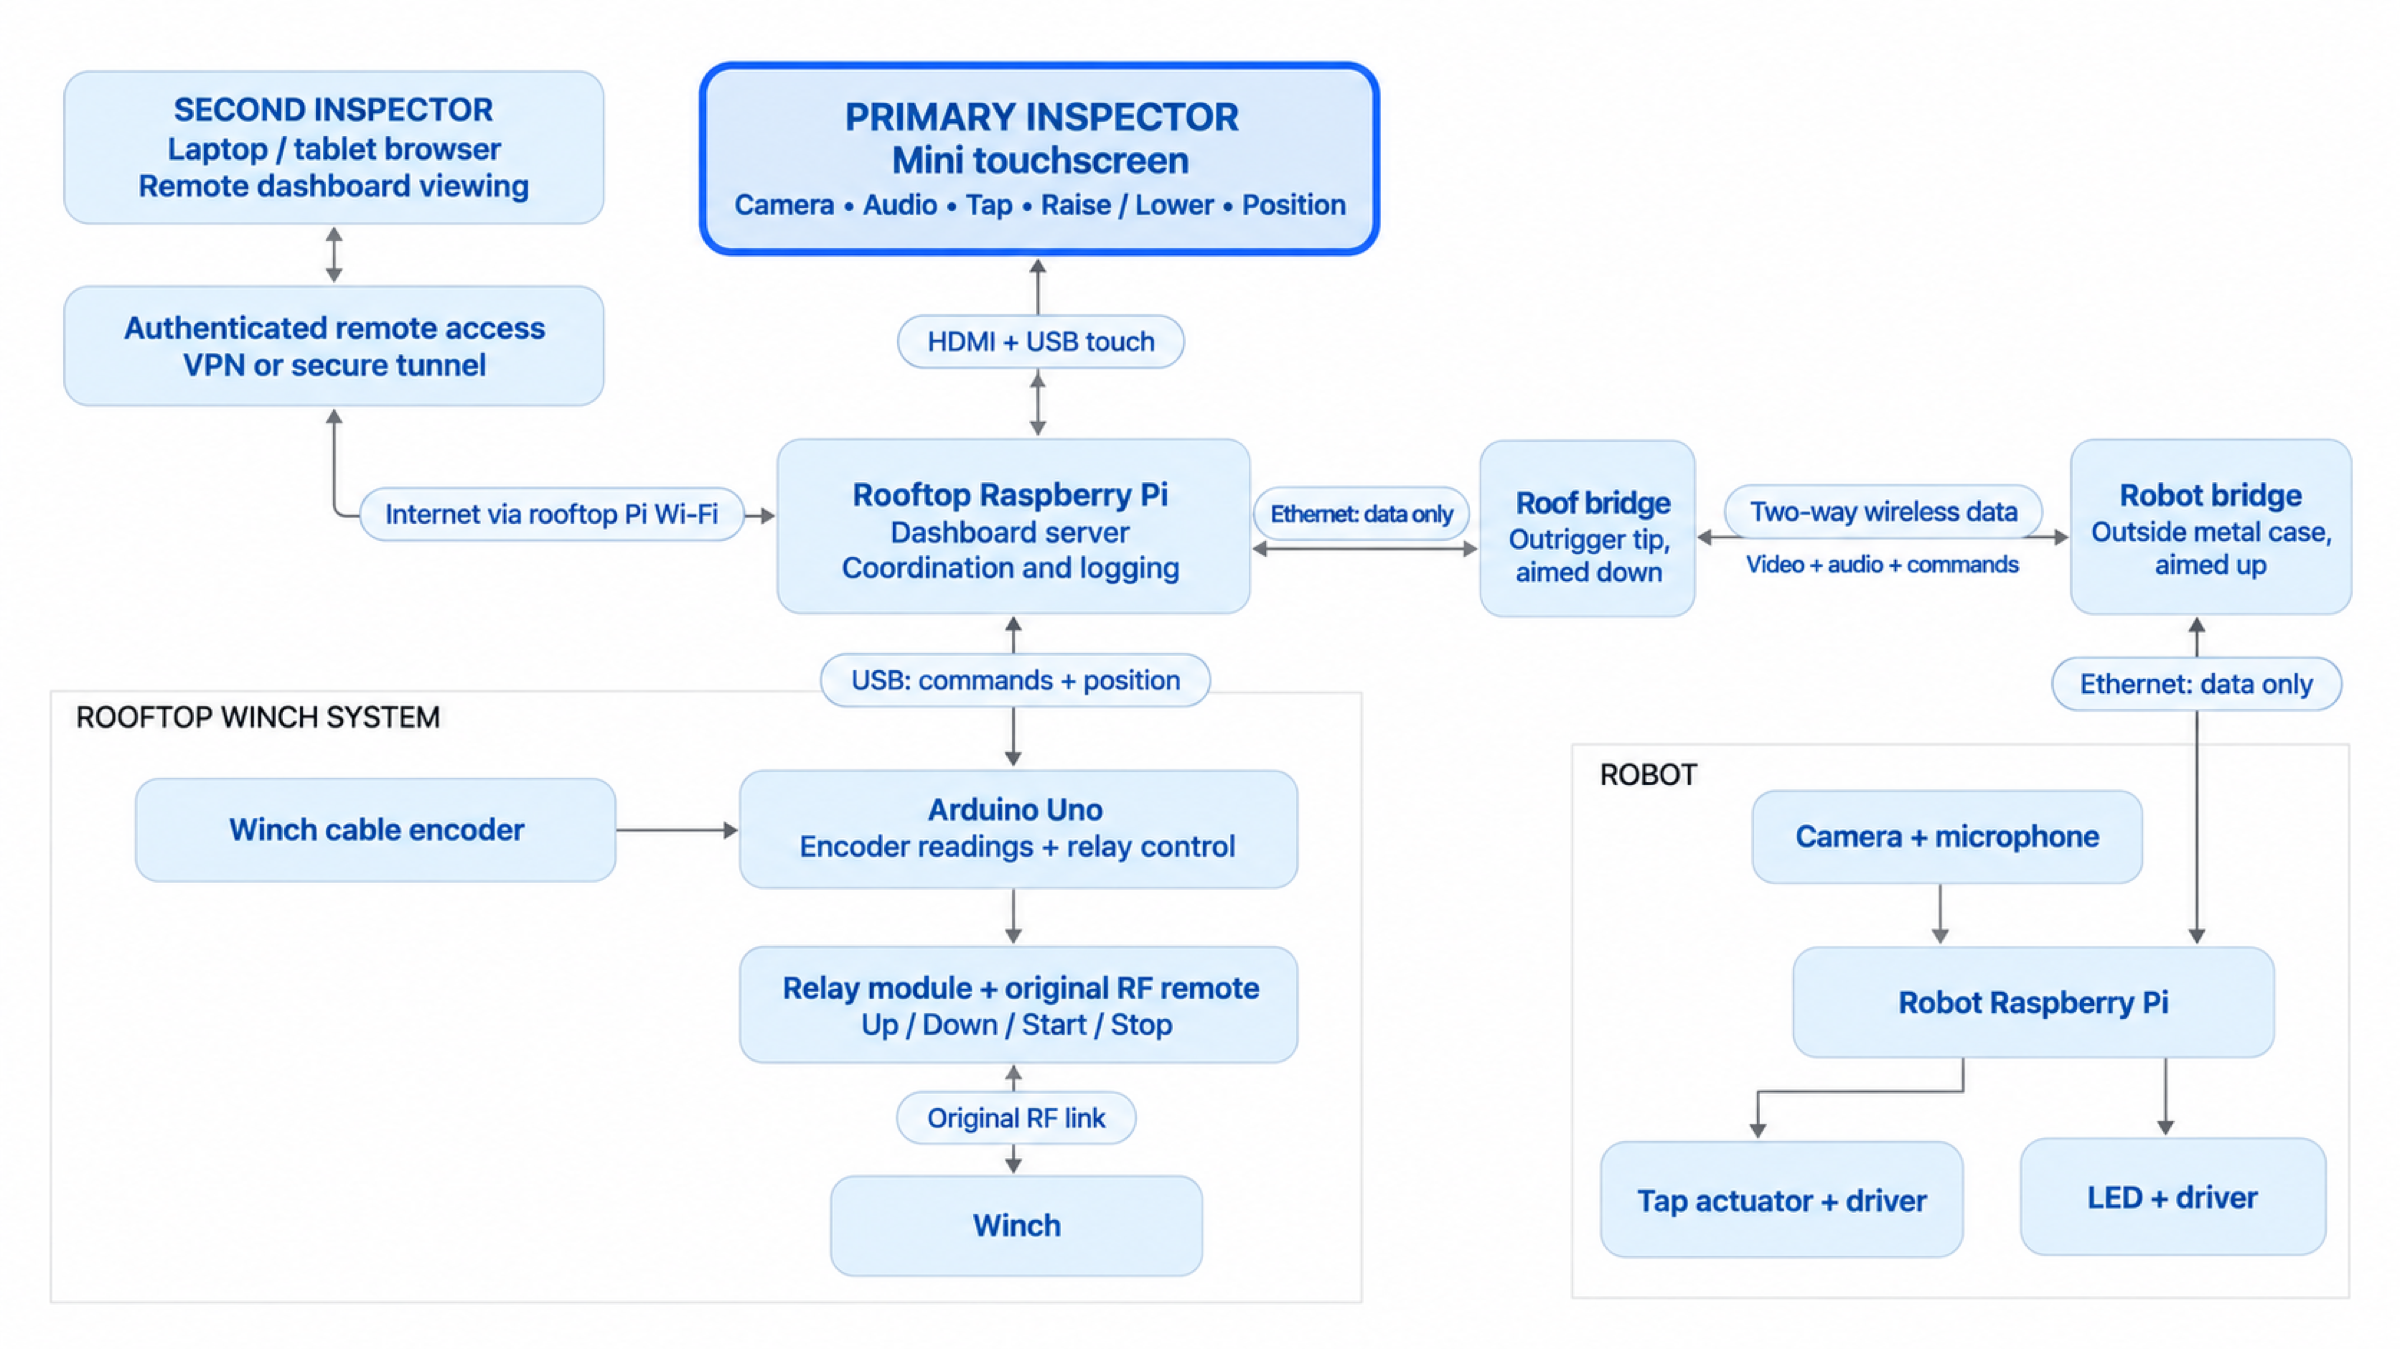
I designed a two-Pi architecture and proposed the wireless Ethernet bridge to carry video, audio, and commands without a long trailing data cable. I also worked with the outrigger team on winch-position sensing and remote-button relay control.
04 Sensing & integration
A useful view, close to the wall.
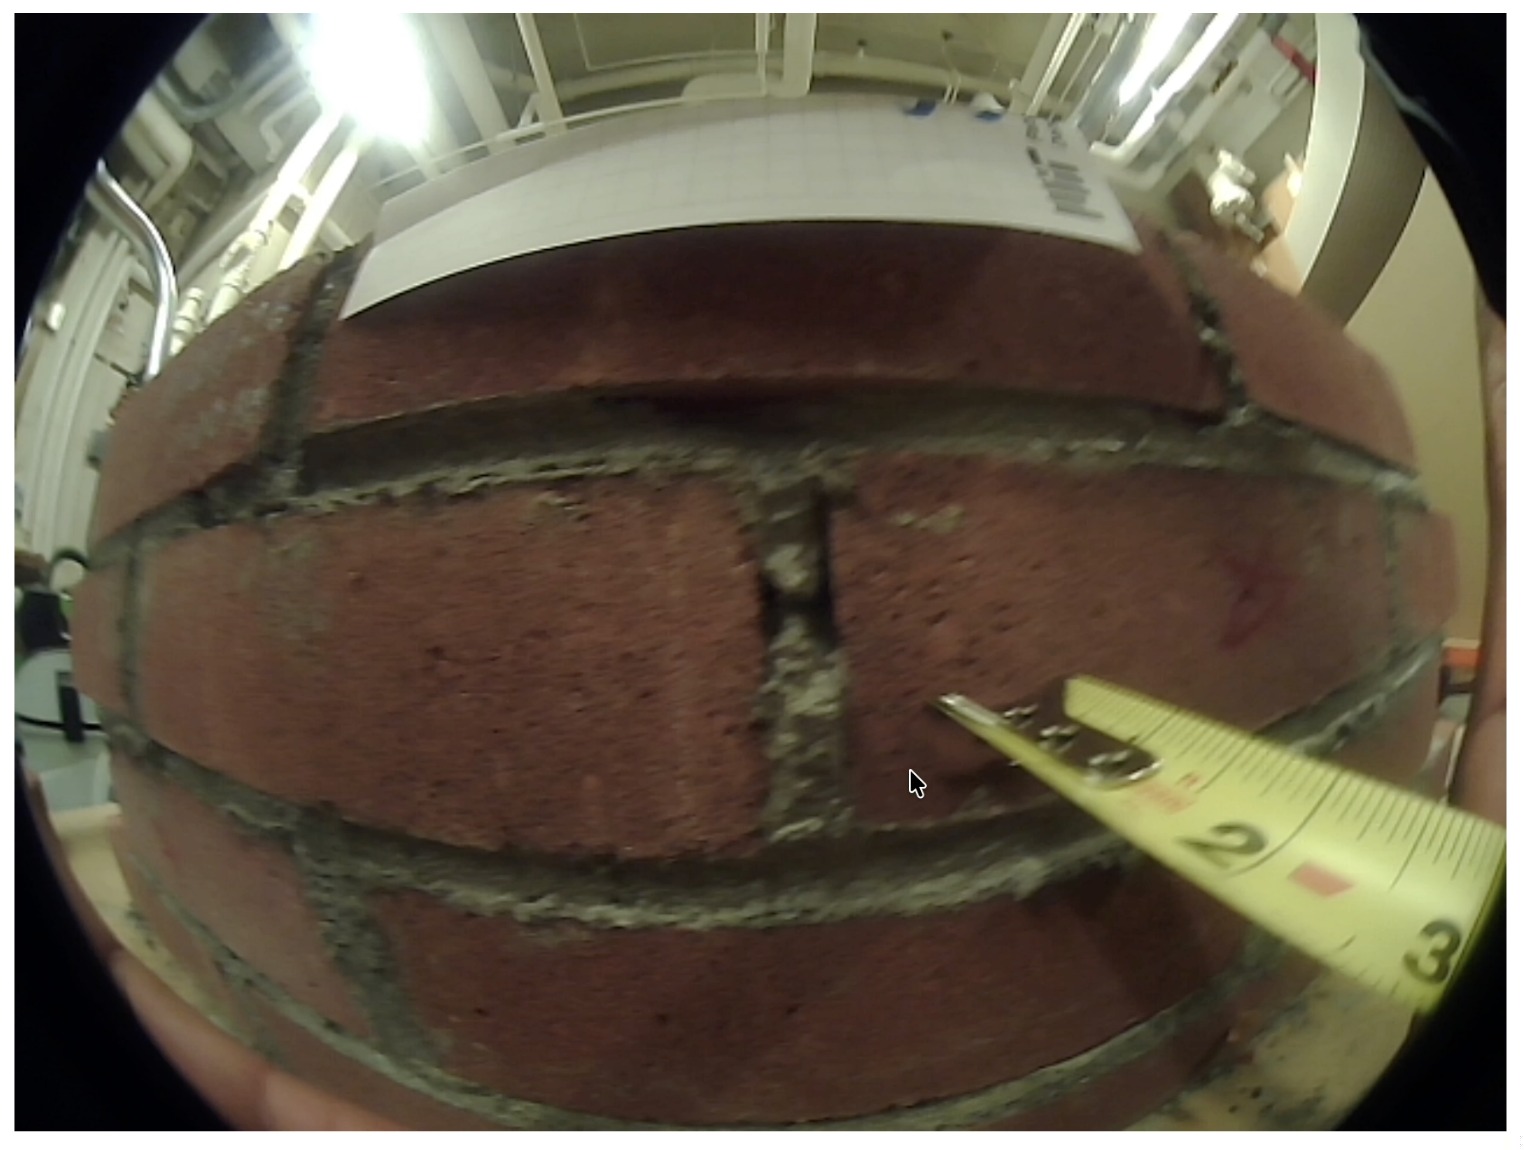
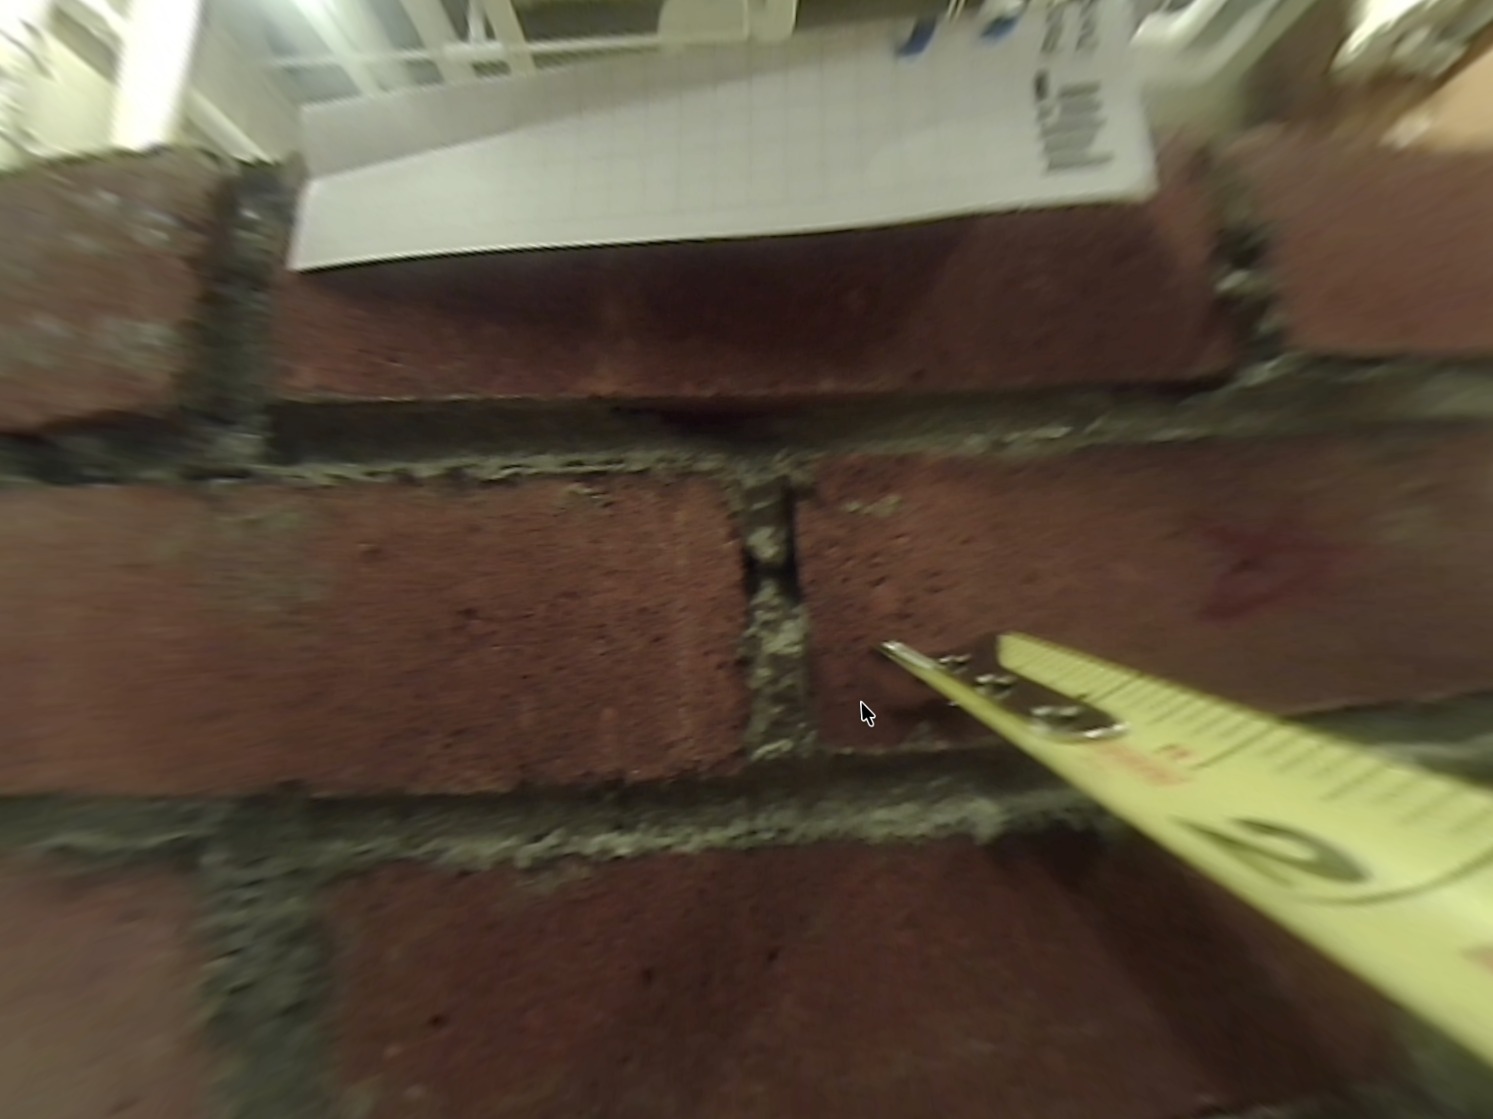
I defined camera and lighting requirements around a three-by-three brick view at a three-inch working distance, calculated the required coverage, and developed fisheye correction for the inspection imagery.
More CAD & integration details
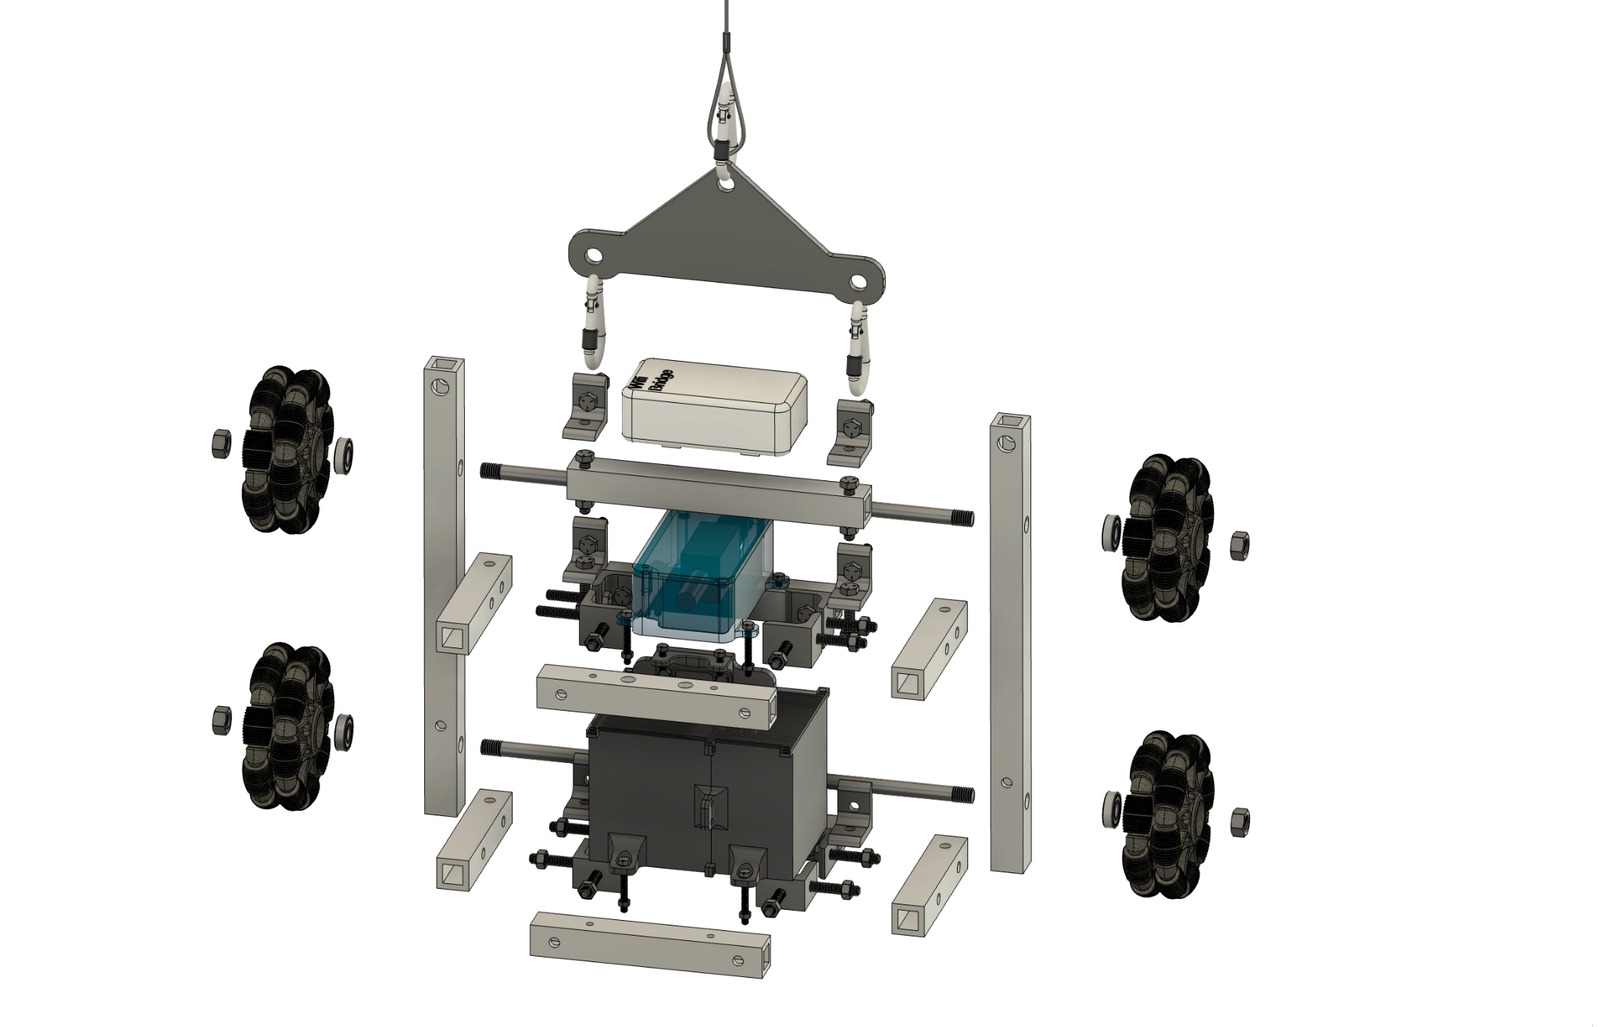
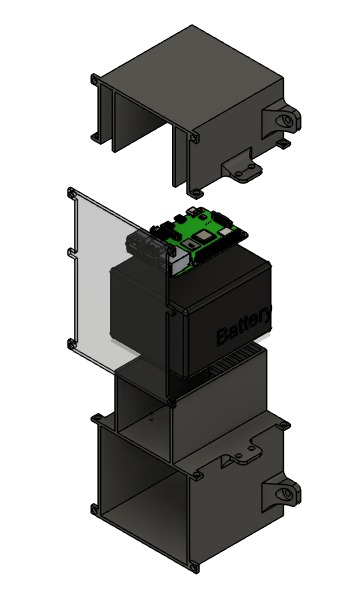
These shared team CAD views show the payload and electronics packaging. My integration work considers component clearances, mounting, service access, and design for manufacturing alongside the mechanical subteam.
Current work: refining the tapper, mechanical packaging, and sensing/control integration as the robot develops.